Robotics Engineer
See some my works below. Send a message to get in touch.
Slideshow Master Thesis
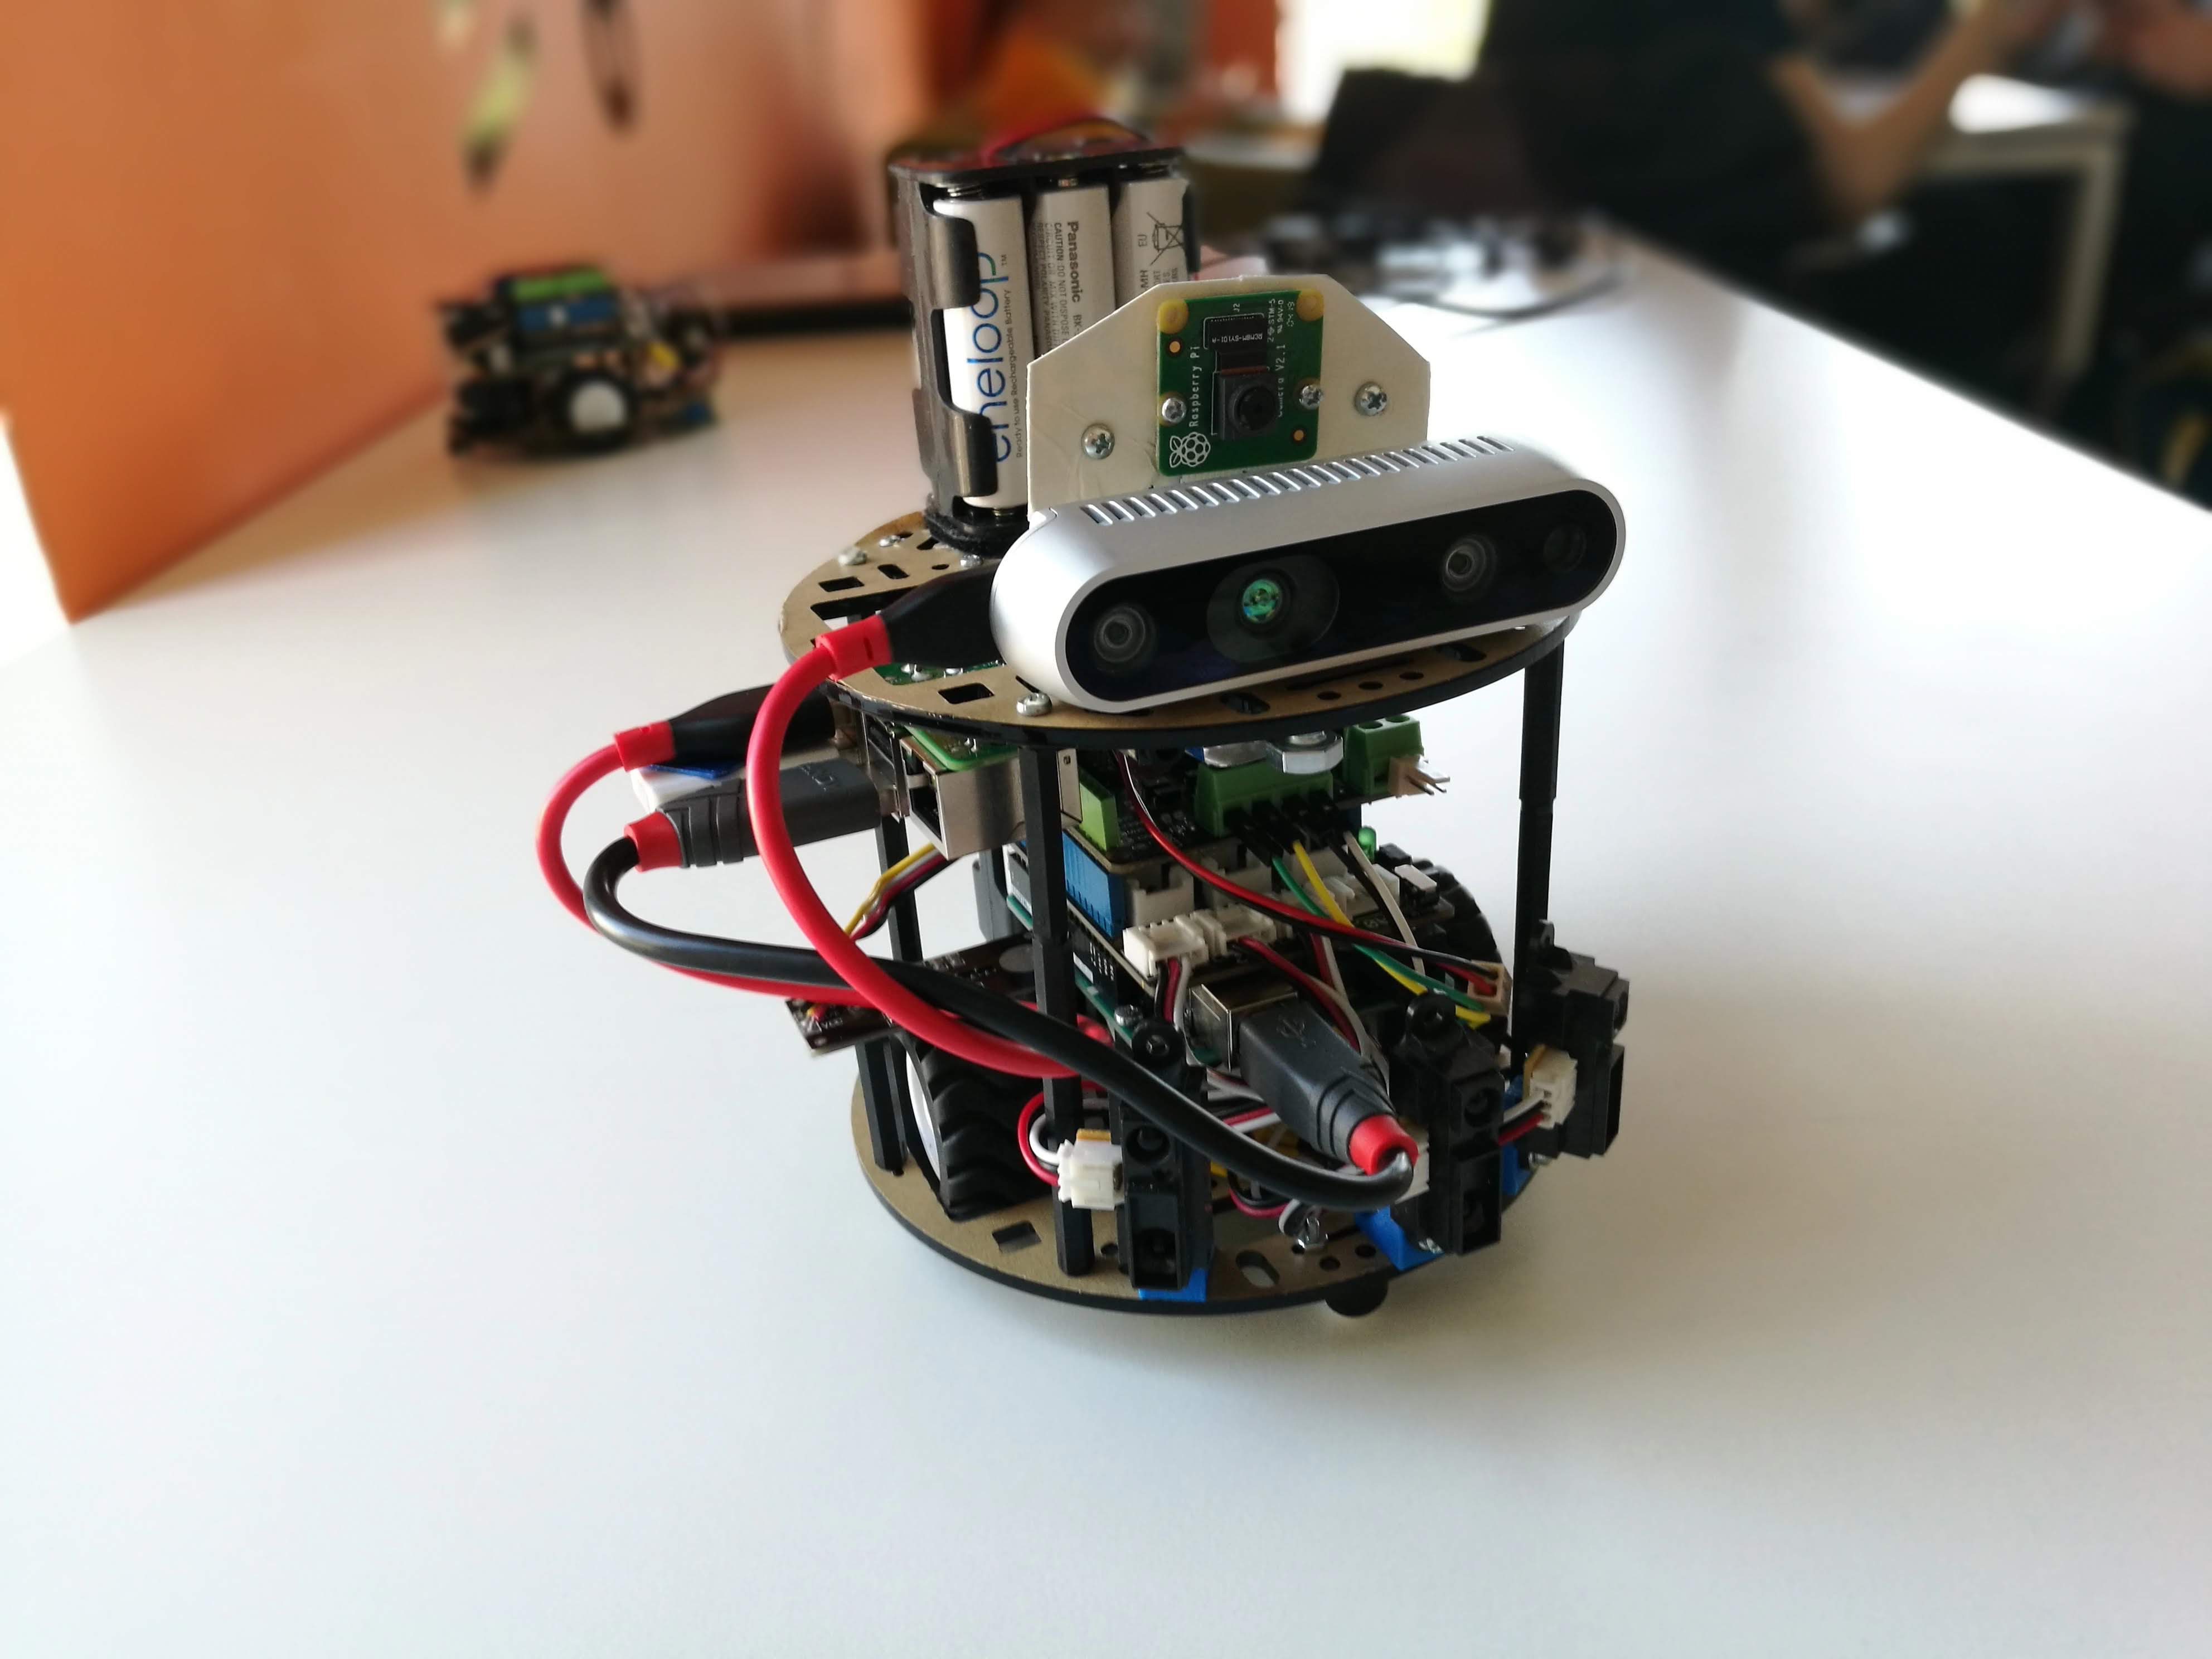
This thesis proposes a design for a small mobile robot controlled by voice. Firstly a preliminary analysis of the state of art of human-robot interaction has been conducted. Then, an analysis of the equipment selected took place, and, later, appropriate methodologies for voice recognition and user detection have been evaluated for this specific case. Finally, an overview of the complete software architecture of the system was given with three possible structures and their comparison. The results obtained show both the feasibility of using low power boards and some of their limitations.
The aim of this project was to implement a control law for a nonlinear system (based on the model of a PVTOL aircraft), using the proper approach depending on the range of settings given in the four subsequent tasks. This shows the various theories and which is to be preferred over to the others, according to the situation to deal with.
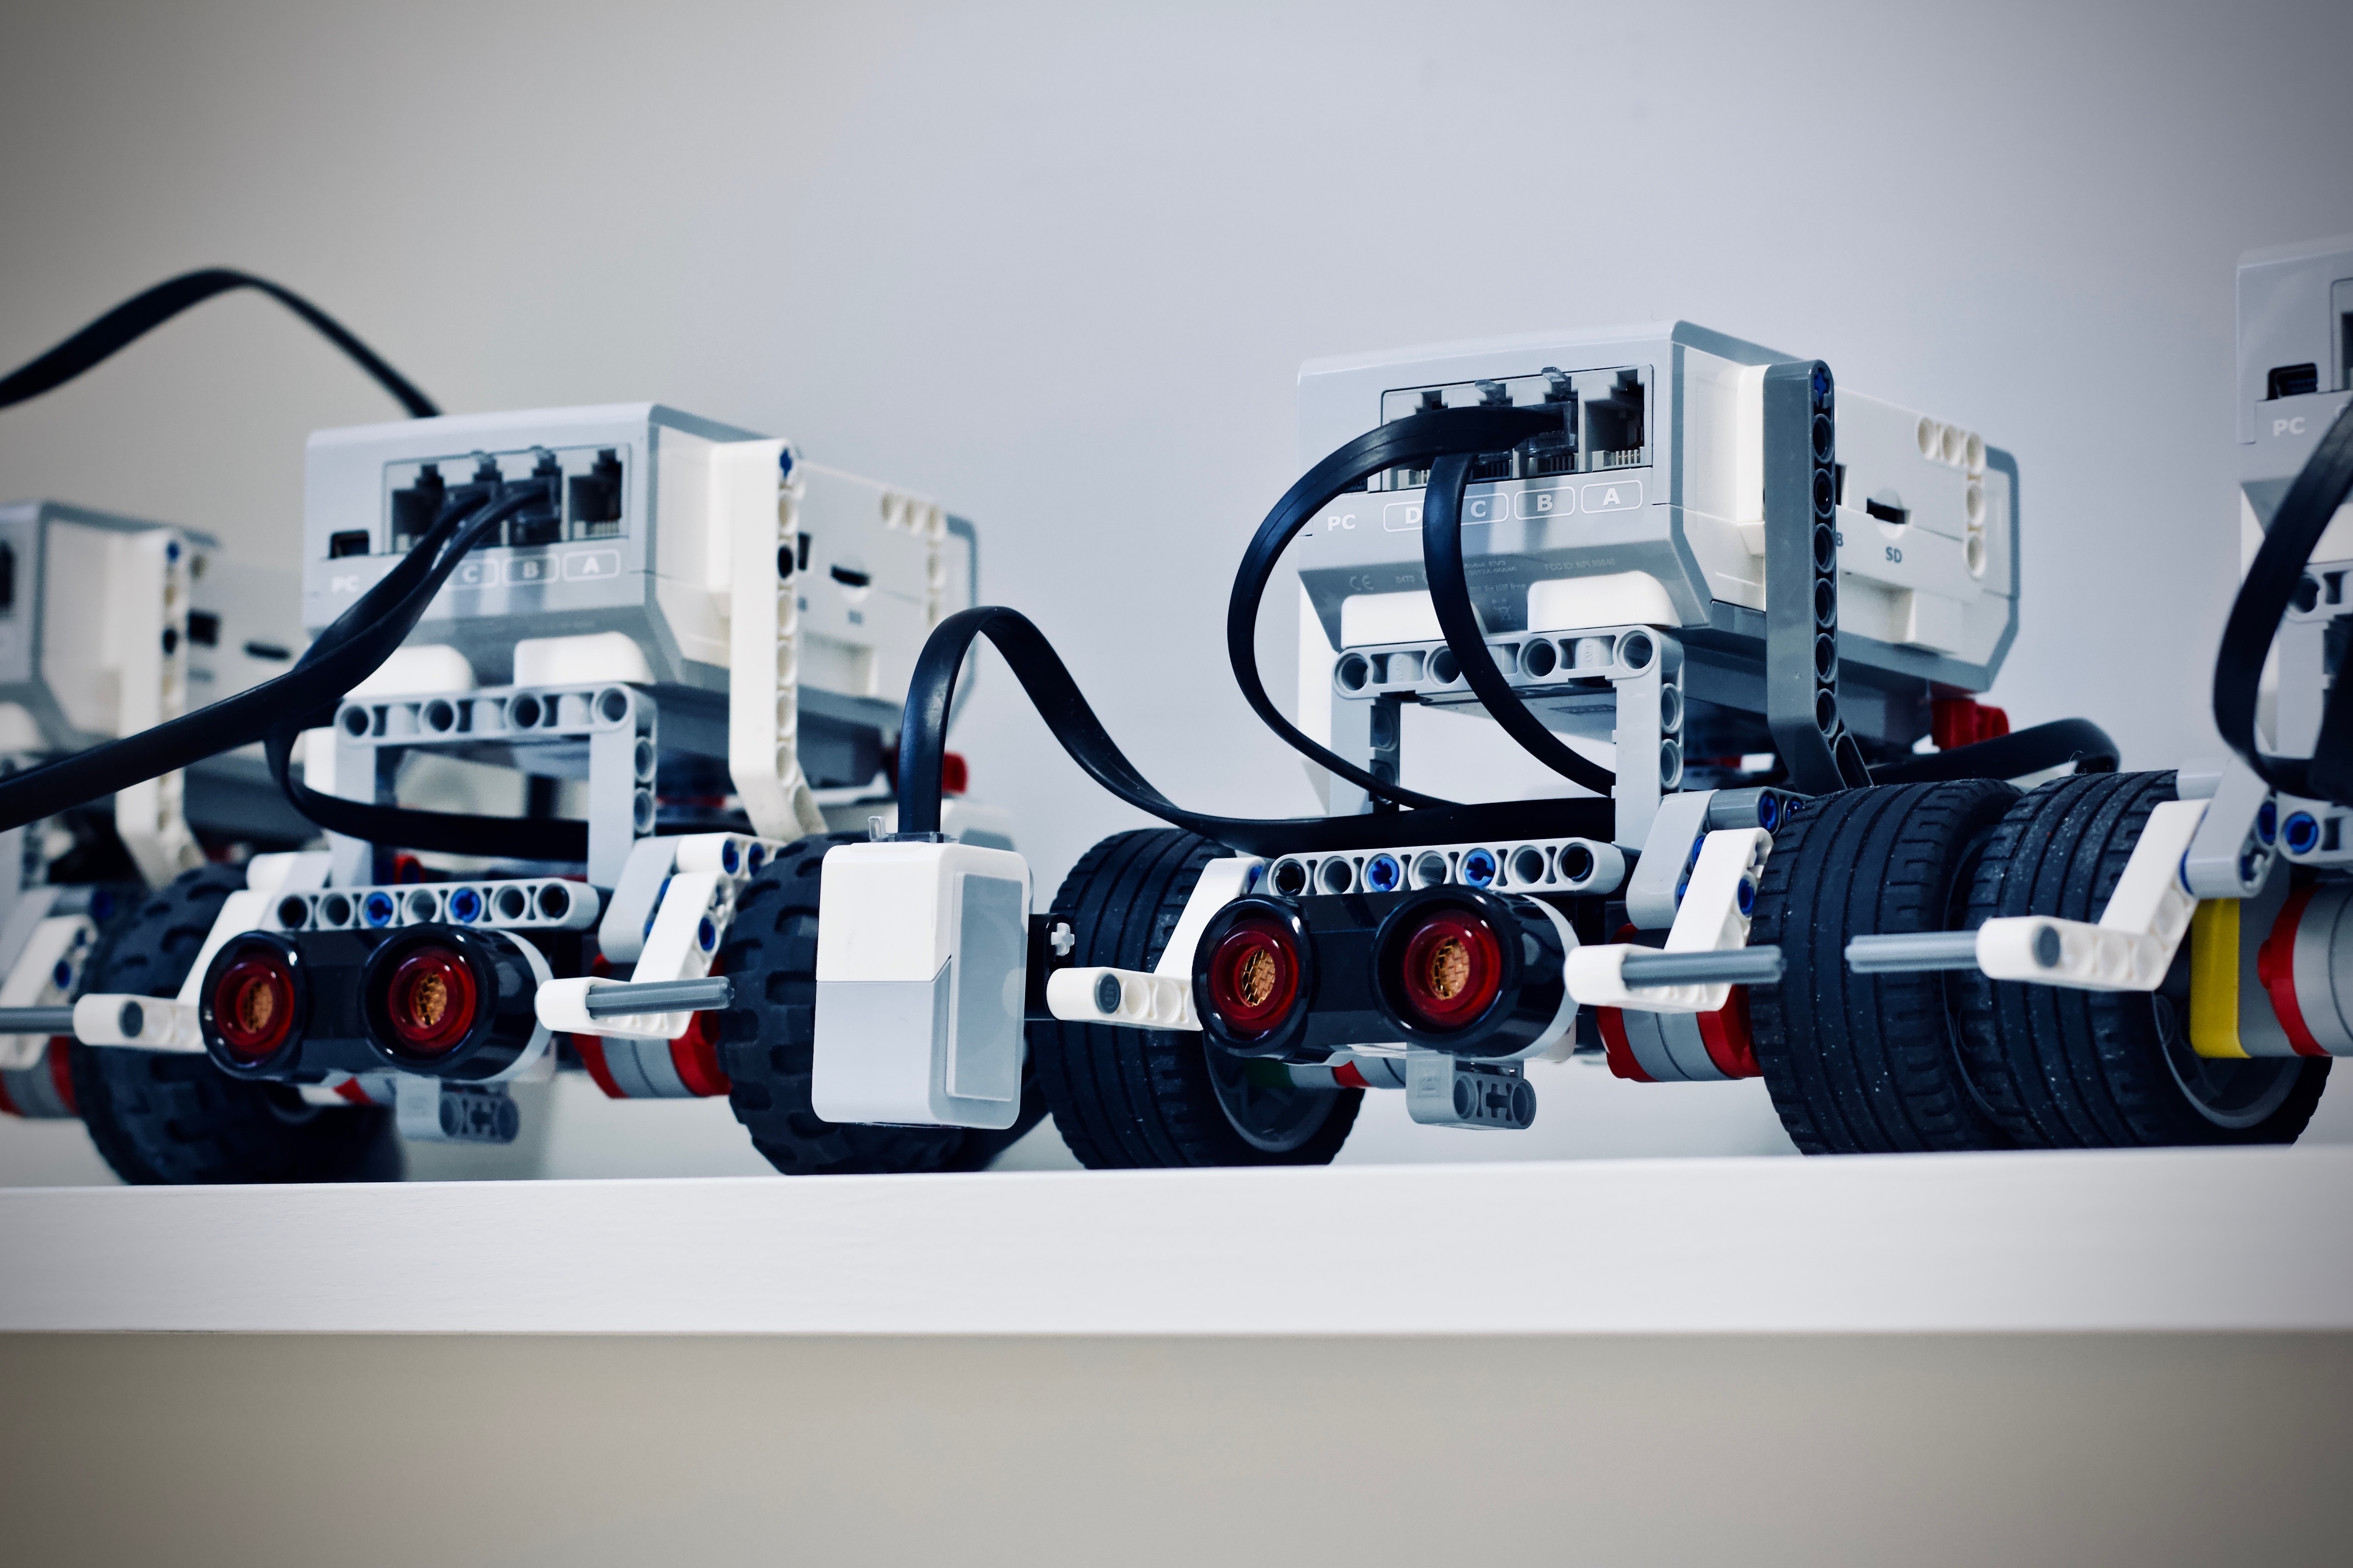
For this project we worked with the data retrieved from a differential drive robot for its localization in a certain area by the means of the Extended Kalman filter (EKF). A first step included the development of a Kalman Filter for the self-localization. This has been then improved by implenting an Extended Kalman Filter that allowed to reduce. Finally a comparison in performance of the two has been done.
The aim of this project was to implement a control law for a nonlinear system (based on the model of a PVTOL aircraft), using the proper approach depending on the range of settings given in the four subsequent tasks. This shows the various theories and which is to be preferred over to the others, according to the situation to deal with.